Hi there! I am a Senior Research Scientist at Nvidia GEAR Lab. I graduated from Carnegie Mellon University’s Robotics Institute, School of Computer Science, advised by Prof. Kris Kitani. I earned my bachelor’s degree from University of Pennsylvania in 2019, where I worked with Prof. Kostas Daniilidis. My research has been supported by Qualcomm Innovation Fellowship and the Meta AI Mentorship Program.
My research interest lies at the intersection of robotics, vision, and learning. I am working on topcis including humanoid control, humnoid-object interaction, egocentric perception etc. Through my research, I want to create methods that effectively interpret spatial-temporal sensory input and build a representation of the 3D world to reason about the interactions between agents and the physical environment. On the application side, I am excited about humanoid robots and AR/VR.

news
| Oct 20, 2026 | GRAIL selected as a Best Paper Award Finalist at CoRL 2026! | |
|---|---|---|
| Sep 4, 2026 | GRAIL (generating humanoid loco-manipulation from world models), CHIP (adaptive compliance for humanoid control), and CHORD (dexterous manipulation from human demonstrations via contact wrench guidance) accepted to CoRL 2026! | |
| Aug 12, 2026 | SONIC (supersizing motion tracking for natural humanoid whole-body control) has been published in Science Robotics! | |
| Feb 27, 2026 | VIRAL (visual sim-to-real at scale for humanoid loco-manipulation) and Doorman (pixel-to-action policy transfer for humanoids) accepted to CVPR 2026! | |
| Jan 22, 2026 | PLD (self-improving VLAs with residual RL data generation) and BFM-Zero (promptable behavioral foundation model for humanoids) accepted to ICLR 2026! | |
| Aug 1, 2025 | UniPhys (end-to-end text to control for simulated humanoids) has been accepted to ICCV 2025 (highlight)! |
Affiliations


Publications

- SONIC: Supersizing Motion Tracking for Natural Humanoid Whole-Body Control
- Zhengyi Luo†, Ye Yuan†, Tingwu Wang†, Chenran Li†, Fernando Castañeda†, Sirui Chen*, Zi-Ang Cao*, Jiefeng Li*, David Minor*, Qingwei Ben*, Jinhyung Park*, David Sami*, Zi Wang*, Xingye Da*, Runyu Ding, Cyrus Hogg, Lina Song, Edy Lim, Eugene Jeong, Tairan He, Haoru Xue, Wenli Xiao, Simon Yuen, Jan Kautz, Yan Chang, Umar Iqbal, Linxi "Jim" Fan, Yuke Zhu
- Science Robotics 2026
- † Co-First Authors, * Core Contributors
- [Paper] [Project] [Code]
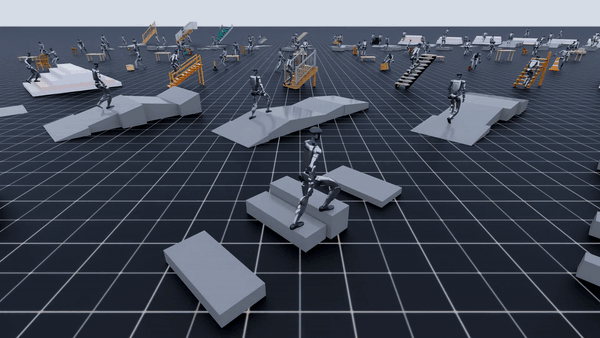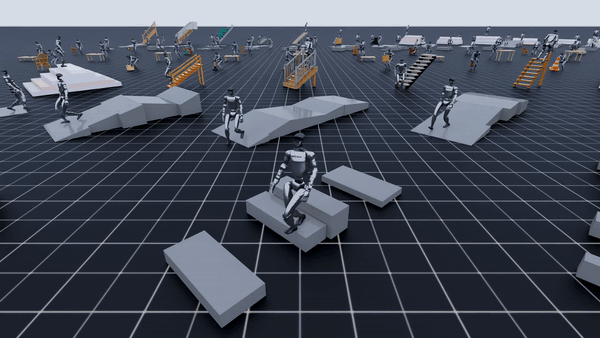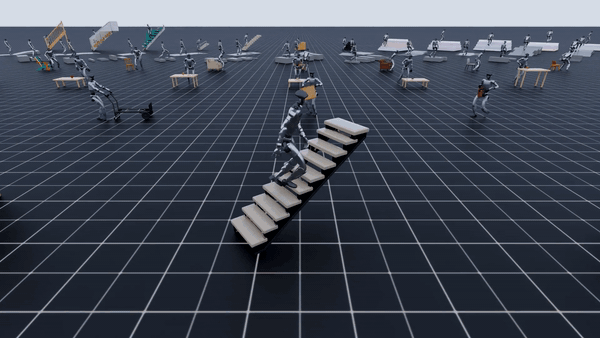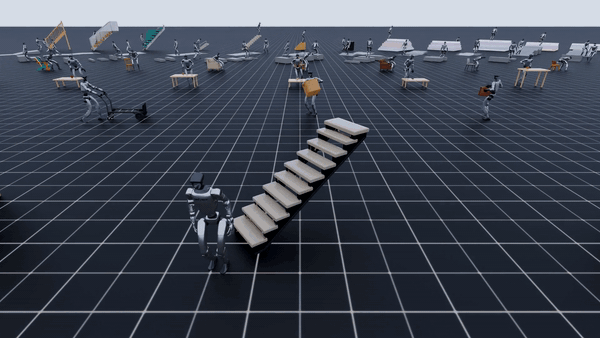
- GRAIL: Generating Humanoid Loco-Manipulation from World Models
- Tianyi Xie*, Haotian Zhang*, Jinhyung Park*, Zi Wang*, Bowen Wen, Jiefeng Li, Xueting Li, Qingwei Ben, Haoyang Weng, Yufei Ye, David Minor, Tingwu Wang, Chenfanfu Jiang, Sanja Fidler, Jan Kautz, Linxi "Jim" Fan, Yuke Zhu, Zhengyi Luo†, Umar Iqbal†, Ye Yuan†
- CoRL 2026 (Best Paper Award Finalist)
- * Co-First Authors, † Project Leads
- [Paper] [Project] [Code]
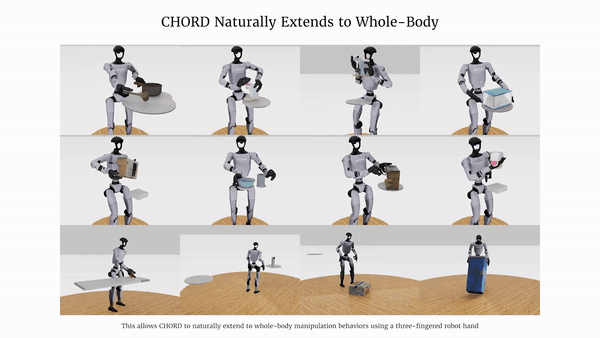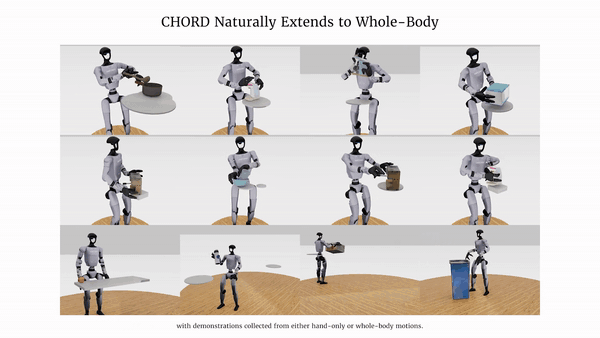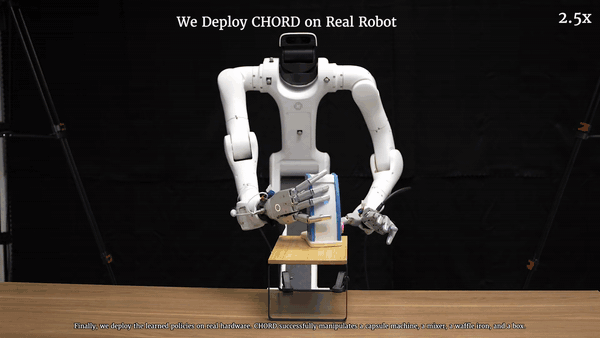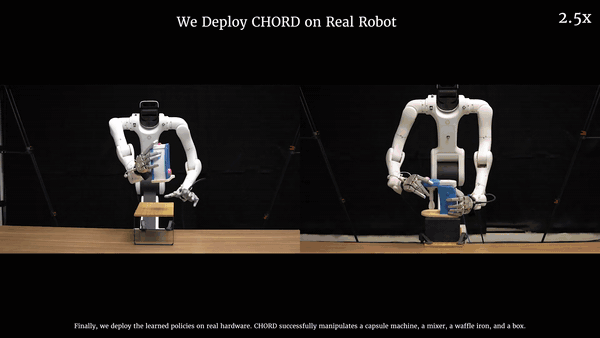
- CHORD: Learning Dexterous Manipulation Using Contact Wrench Guidance from Human Demonstration
- Xinghao Zhu*, Zixi Liu*, Shalin Jain*, Chenran Li, Milad Noori, Michael Andres Lin, Huihua Zhao, John Welsh, Mrinal Verghese, Wei Liu, Tingwu Wang, Xingye Da, Zhengyi Luo, Vishal Kulkarni, Naema Bhatti, Yuke Zhu, Linxi "Jim" Fan, Bowen Wen, Danfei Xu, Soha Pouya, Yan Chang
- CoRL 2026
- * Equal contribution
- [Paper] [Project] [Code]


- BFM-Zero: A Promptable Behavioral Foundation Model for Humanoid Control Using Unsupervised Reinforcement Learning
- Yitang Li*, Zhengyi Luo*, Tonghe Zhang, Cunxi Dai, Anssi Kanervisto, Andrea Tirinzoni, Haoyang Weng, Kris Kitani, Mateusz Guzek, Ahmed Touati, Alessandro Lazaric, Matteo Pirotta, Guanya Shi
- ICLR 2026
- * Equal contribution
- [Paper] [Project]


- Learning Universal Humanoid Control
- Zhengyi Luo
- PhD Thesis
- [Paper]


- Emergent Active Perception and Dexterity of Simulated Humanoids from Visual Reinforcement Learning
- Zhengyi Luo*, Chen Tessler*, Toru Lin, Ye Yuan, Tairan He, Wenli Xiao, Yunrong Guo, Gal Chechik, Kris Kitani, Linxi "Jim" Fan, Yuke Zhu
- 1st Workshop on Humanoid Agents, CVPR 2025 (Best Paper Award)
- * Equal contribution
- [Paper] [Project]

- ASAP: Aligning Simulation and Real-World Physics for Learning Agile Humanoid Whole-Body Skills
- Tairan He*, Jiawei Gao*, Wenli Xiao*, Yuanhang Zhang*, Zi Wang, Jiashun Wang, Zhengyi Luo, Guanqi He, Nikhil Sobanbab, Chaoyi Pan, Zeji Yi, Guannan Qu, Kris Kitani, Jessica Hodgins, Linxi Fan, Yuke Zhu
- RSS 2025
- [Paper] [Project] [Code]


- SMPLOlympics: Sports Environments for Physically Simulated Humanoids
- Zhengyi Luo*, Jiashun Wang*, Kangni Liu*, Haotian Zhang, Chen Tessler, Jingbo Wang, Ye Yuan, Jinkun Cao, Zihui Lin, Fengyi Wang, Jessica Hodgins, Kris Kitani
- 1st Workshop on Humanoid Agents, CVPR 2025
- * Equal contribution
- [Paper] [Project] [Code]


- PACER+: On-Demand Pedestrian Animation Controller in Driving Scenarios
- Jingbo Wang*, Zhengyi Luo*, Ye Yuan, Yixuan Li, Bo Dai
- CVPR 2024
- * Equal contribution
- [Paper]


- Learning Human Dynamics in Autonomous Driving Scenarios
- Jingbo Wang, Ye Yuan, Zhengyi Luo, Kevin Xie, Dahua Lin, Umar Iqbal, Sanja Fidler, Sameh Khamis
- ICCV 2023
- [Paper]




- Learning Shape Representations for Clothing Variations in Person Re-Identification
- Yu-Jhe Li, Zhengyi Luo, Xinshuo Weng, Kris M. Kitani
- arXiv, 2020
- [Paper]

- Cross-Domain 3D Equivariant Image Embeddings
- Carlos Esteves, Avneesh Sud, Zhengyi Luo, Kostas Daniilidis, Ameesh Makadia
- ICML 2019
- [Paper]


---
Professional Services
Conference Reviewer: ICML, ICLR, NeurIPS, CVPR, ICCV, ECCV, CoRL, ICRA, RSS, IROS, SIGGRAPH
Journal Reviewer: IJCV, TMM, RA-L